
Opinion & Briefings
Industry briefings, distilled for engineers
Daily industry briefings distilled from robotics research and industrial automation news — each links back to its original source.
ArchiveOpinion · May 19, 2023
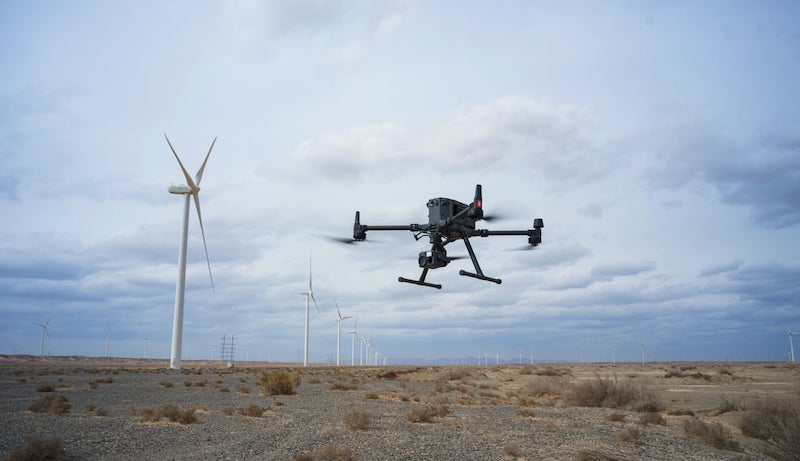
DJI Launches Matrice 350 RTK, a New Standard for Commercial Drones
DJI's new Matrice 350 RTK offers 55-min flight, 2.7 kg payload, and advanced safety features for commercial operations.
Read moreArchiveOpinion · May 9, 2023
Variable-Stiffness Lower-Limb Exoskeleton for Safe Rehabilitation
A reconfigurable variable-stiffness actuator enables a lower-limb exoskeleton to adjust joint stiffness over a wide range, improving safety and comfort in rehabilitation.
Read moreArchiveOpinion · May 9, 2023
Robust LiDAR-IMU Joint Calibration Method Handles Occluded Environments
A new calibration method uses line features and adaptive weighting to achieve high accuracy even in complex, occluded scenes.
Read moreArchiveOpinion · May 9, 2023
Hybrid Parametric and Non-Parametric Calibration Boosts Dual-Arm Robot Cooperative Positioning Accuracy
A kinematic calibration method combining parametric and non-parametric models reduces dual-arm cooperative positioning error to 0.1676 mm, a 27.7% improvement over parametric-only methods.
Read moreArchiveOpinion · May 9, 2023
Pneumatic Bistable Device Drives Squid-Inspired Soft Robot to 0.58 BL/s
Researchers design a squid-inspired soft robot using a pneumatic bistable device for water-jet propulsion, achieving 8.7 cm/s (0.58 body lengths/s) with load capacity.
Read moreArchiveOpinion · May 9, 2023
Tensegrity-Based Bionic Legged Robot Design
Researchers propose a tensegrity-based bionic leg design with a single motor, simplifying control and improving adaptability.
Read moreArchiveOpinion · May 9, 2023
Topological Map-Based RRT Improves Mobile Robot Autonomous Exploration Efficiency
Researchers propose TMRRT algorithm combining topological maps with RRT to reduce repeated exploration, cutting exploration time by up to 15.7% and path length by 34.3%.
Read moreArchiveOpinion · May 9, 2023
Reinforcement Learning-Based Peg-in-Hole Assembly with Fuzzy Reward DDPG
A DDPG-based variable admittance control with fuzzy reward improves robotic peg-in-hole assembly in unstructured environments, completing tasks within 10 steps after convergence.
Read moreArchiveOpinion · May 9, 2023
Free-Force Control of 6-RUS Parallel Robot Using Generalized Coordinate Dynamics
A generalized-coordinate dynamics model enables efficient free-force control for a 6-RUS parallel spraying robot, reducing required end torque to 2.2 N·m.
Read more