Opinion & Briefings
Industry briefings, distilled for engineers
Daily industry briefings distilled from robotics research and industrial automation news — each links back to its original source.
BriefingOpinion · May 22, 2026
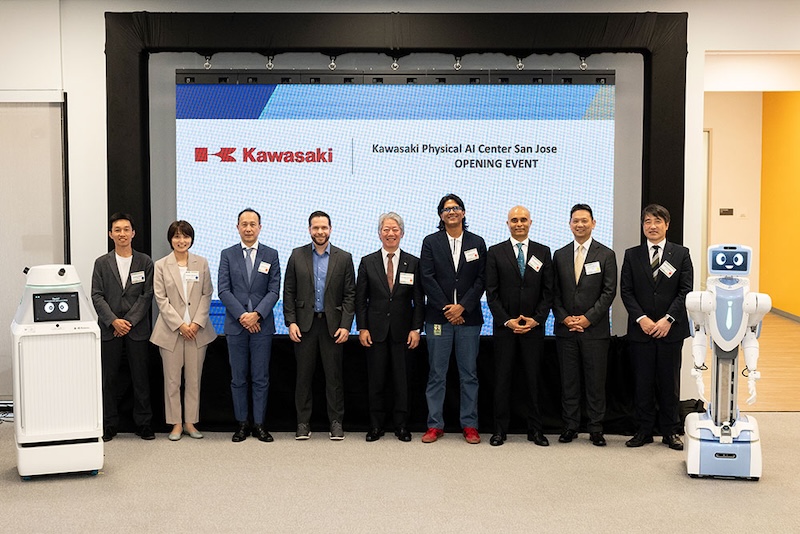
Kawasaki Opens Silicon Valley Physical AI Center to Accelerate Real-World Robotics
Kawasaki Heavy Industries launches a San Jose hub with Nvidia, Analog Devices, Microsoft, and Fujitsu to develop physical AI for healthcare and elder care.
Read more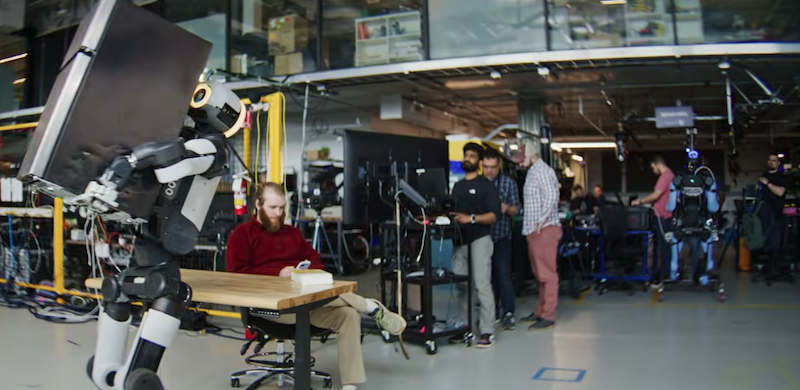
BriefingOpinion · May 20, 2026
Boston Dynamics Trains Atlas Humanoid to Lift and Place Heavy Appliances
New footage shows electric Atlas handling a 50-lb fridge, with AI control for whole-body manipulation aimed at industrial tasks.
Read moreBriefingOpinion · May 12, 2026
Vision-Based Pose Detection for Dynamic Docking of Unmanned Surface Vehicles
A stereo marker and robust recognition method enable reliable pose estimation for USV dynamic docking under large angles, motion blur, and occlusion.
Read moreBriefingOpinion · May 12, 2026
Thrust Feedback Control Method Enhances Rotor UAV Precision in Wind
Researchers propose a thrust feedback-based control method for multirotor UAVs, using force sensors and closed-loop control to improve accuracy and stability under wind disturbances.
Read moreBriefingOpinion · May 12, 2026
Emotion Recognition Network with Asymmetric Attention and Dual Pooling Screening
AADPS network fuses facial and body cues with asymmetric attention and dual pooling key-frame screening, achieving 94.95% and 88.69% accuracy on FABO and CAER datasets.
Read moreBriefingOpinion · May 12, 2026
Optimized Variable-Stiffness Actuator with Inverse Proportional Curve Groove
A new VSA design using inverse proportional function curve grooves linearizes stiffness curves, achieving under 4% nonlinear error and decoupled stiffness for safer collaborative robots.
Read moreBriefingOpinion · May 12, 2026
Dynamics-Driven Optimization Suppresses Residual Vibration in Cable-Driven Continuum Robots
A new method using NURBS-parameterized cable-length driving reduces residual vibration by up to 84.5% in fast and medium-speed motions.
Read moreBriefingOpinion · May 12, 2026
Underwater 3D Terrain Reconstruction from Side-Scan Sonar Using BFGS-ADMM
Researchers propose a shape-from-shading method combining BFGS and ADMM to reconstruct 3D seabed terrain from 2D side-scan sonar images, improving accuracy and efficiency.
Read moreBriefingOpinion · May 12, 2026
Tracked Robot With Hybrid Force/Position Control for Underwater Cleaning of Hydraulic Structures
A tracked underwater cleaning robot with neural-network adaptive PID force control and ESO-based robust MPC achieves ±1 N force and ±2 mm trajectory accuracy in field tests.
Read more