
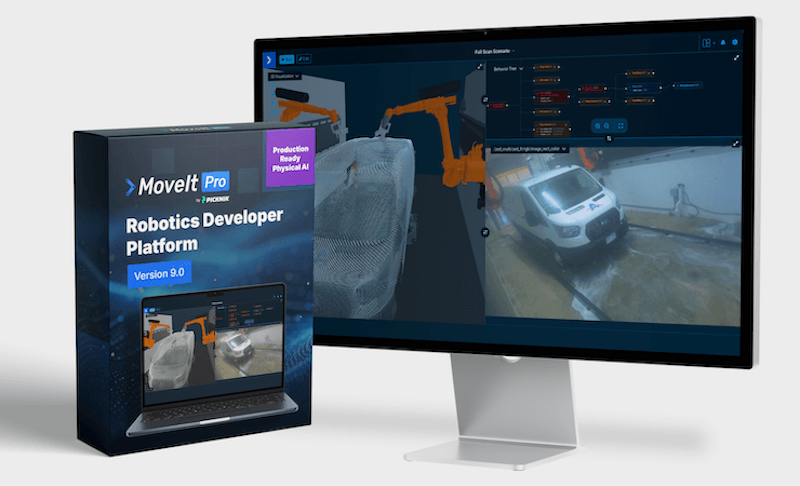
PickNik has released version 9 of its robotics development software MoveIt Pro, introducing new capabilities aimed at improving how robots operate in complex, real-world environments such as cleaning, sanitation, and vehicle washing. The update focuses on “scan-and-plan” workflows, enabling robots to perceive their surroundings in real time and generate motion paths dynamically rather than relying on fixed, pre-programmed instructions.
Key takeaways
- MoveIt Pro 9.0 strengthens perception-to-motion capabilities with AI-based perception filtering, point cloud alignment, and collision-aware motion planning.
- New features include automated contour extraction and rasterized Cartesian path generation from point clouds, plus AI-driven 2D mask filtering and bounding box analysis for improved perception reliability.
- The software is already deployed in vehicle care (Autowash), restroom cleaning (Hivebotics), and food processing sanitation (CleanBotix), enabling adaptation to variable geometries and layouts.
- Updates also cover teleoperation, training data collection, and a redesigned user interface for better debugging and workflow configuration.
These developments reflect a broader trend toward adaptive robotics, where real-time perception and AI handle tasks previously difficult to automate due to environmental variability. MoveIt Pro 9.0 is available now.
Source: Robotics & Automation News (roboticsandautomationnews.com) · Published 2026-04-09 · “PickNik releases MoveIt Pro 9 to improve AI-driven robotics in variable environments”