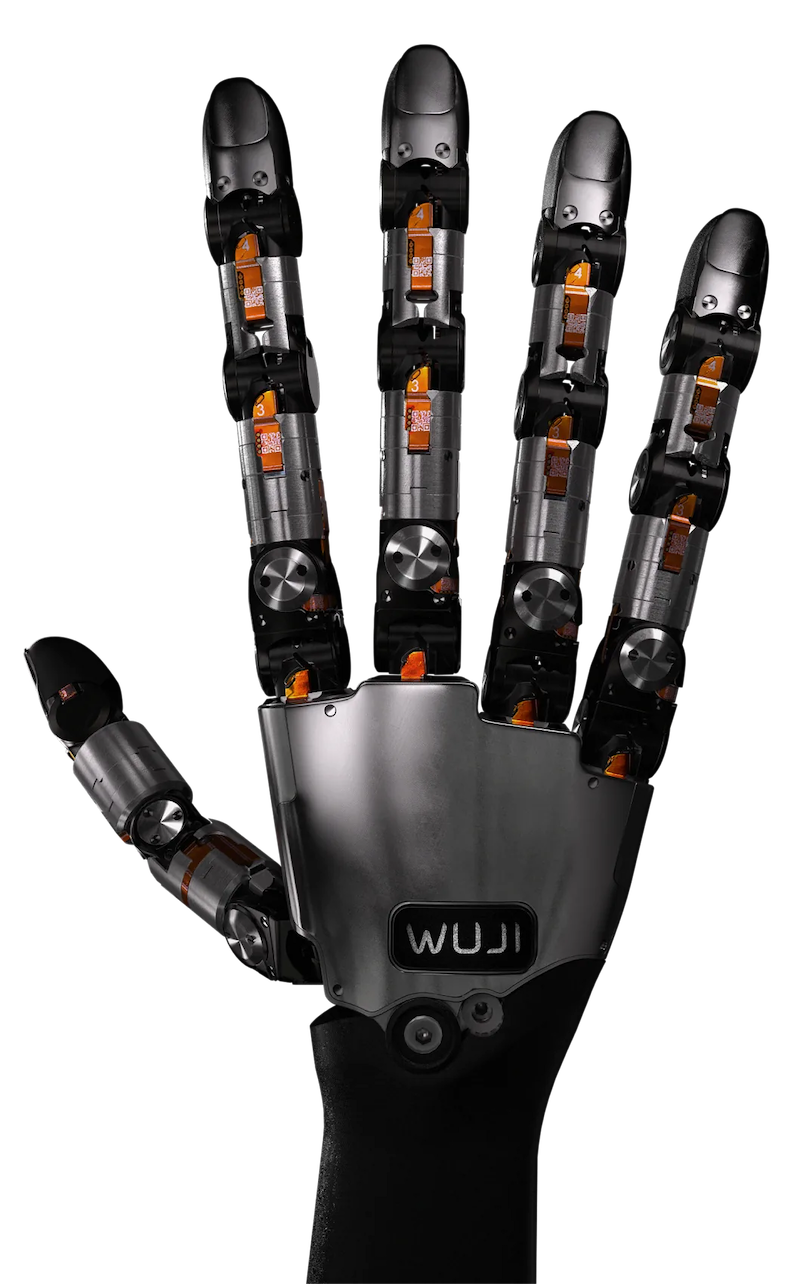
Scientists at ETH Zurich have demonstrated an anthropomorphic robotic hand that uses its fingers for locomotion as well as manipulation, allowing it to crawl, steer and recover from falls without a separate mobility system. The research used an off-the-shelf dexterous hand from WUJI rather than mounting it on a conventional robot arm or mobile base. The work appears in the paper “Fingers as Legs: Learning Self-Supported Locomotion and Manipulation with an Anthropomorphic Hand,” by Amirhossein Kazemipour, Hehui Zheng and Robert Katzschmann.
Key takeaways
- Reinforcement learning was used to develop locomotion, accounting for the unequal dimensions and characteristics of individual fingers.
- Training took place in simulation, with the environment calibrated using measurements from the physical hardware; the researchers report their reward formulation let the hand move faster in simulation than tuned rewards originally developed for quadruped robots.
- The physical system carried onboard power and computation, operating as a self-contained, untethered platform capable of crawling, steering and post-fall recovery.
- While supporting itself, the hand pressed successive keyboard keys without vision and used overhead visual feedback to push an object toward target positions.
The researchers describe the result as a compact mobile manipulator that removes the need for a dedicated locomotion mechanism, letting the same mechanisms perform both movement and physical interaction. The work also reflects the growing use of commercially available dexterous hands as research platforms for robot learning. WUJI has extended this direction with its WUJI Hand 2 and WUJI Glove, demonstrated at IROS 2026 in Pittsburgh, where the glove controlled the hand in real time to capture human motion. Such teleoperation is increasingly used as a data-generation tool for embodied AI, and WUJI is among hardware makers providing native support for Nvidia Isaac Teleop.
Source: Robotics & Automation News · Published 2026-10-16T07:43:07 · “ETH Zurich scientists turn WUJI robotic hand into self-propelled mobile manipulator”